|
Dean Fortier I'm a research engineer at Microsoft Research in Redmond, where I support a team building models for physical AI. I am fairly new to research, but prior to this I have been a Robotics Software Engineer at Optitrack supporting their ROS package and linux compatibility and Fresh Consulting where I supported various robotics related engineering projects listed below. |
|
Research PortfolioI'm interested in robotics, computer vision, electronics, firmware, and deep learning. Most of my work is at the intersection of hardware, software, and control. |
|
Rho: A Foundation for Efficiently Adaptable VLA Models
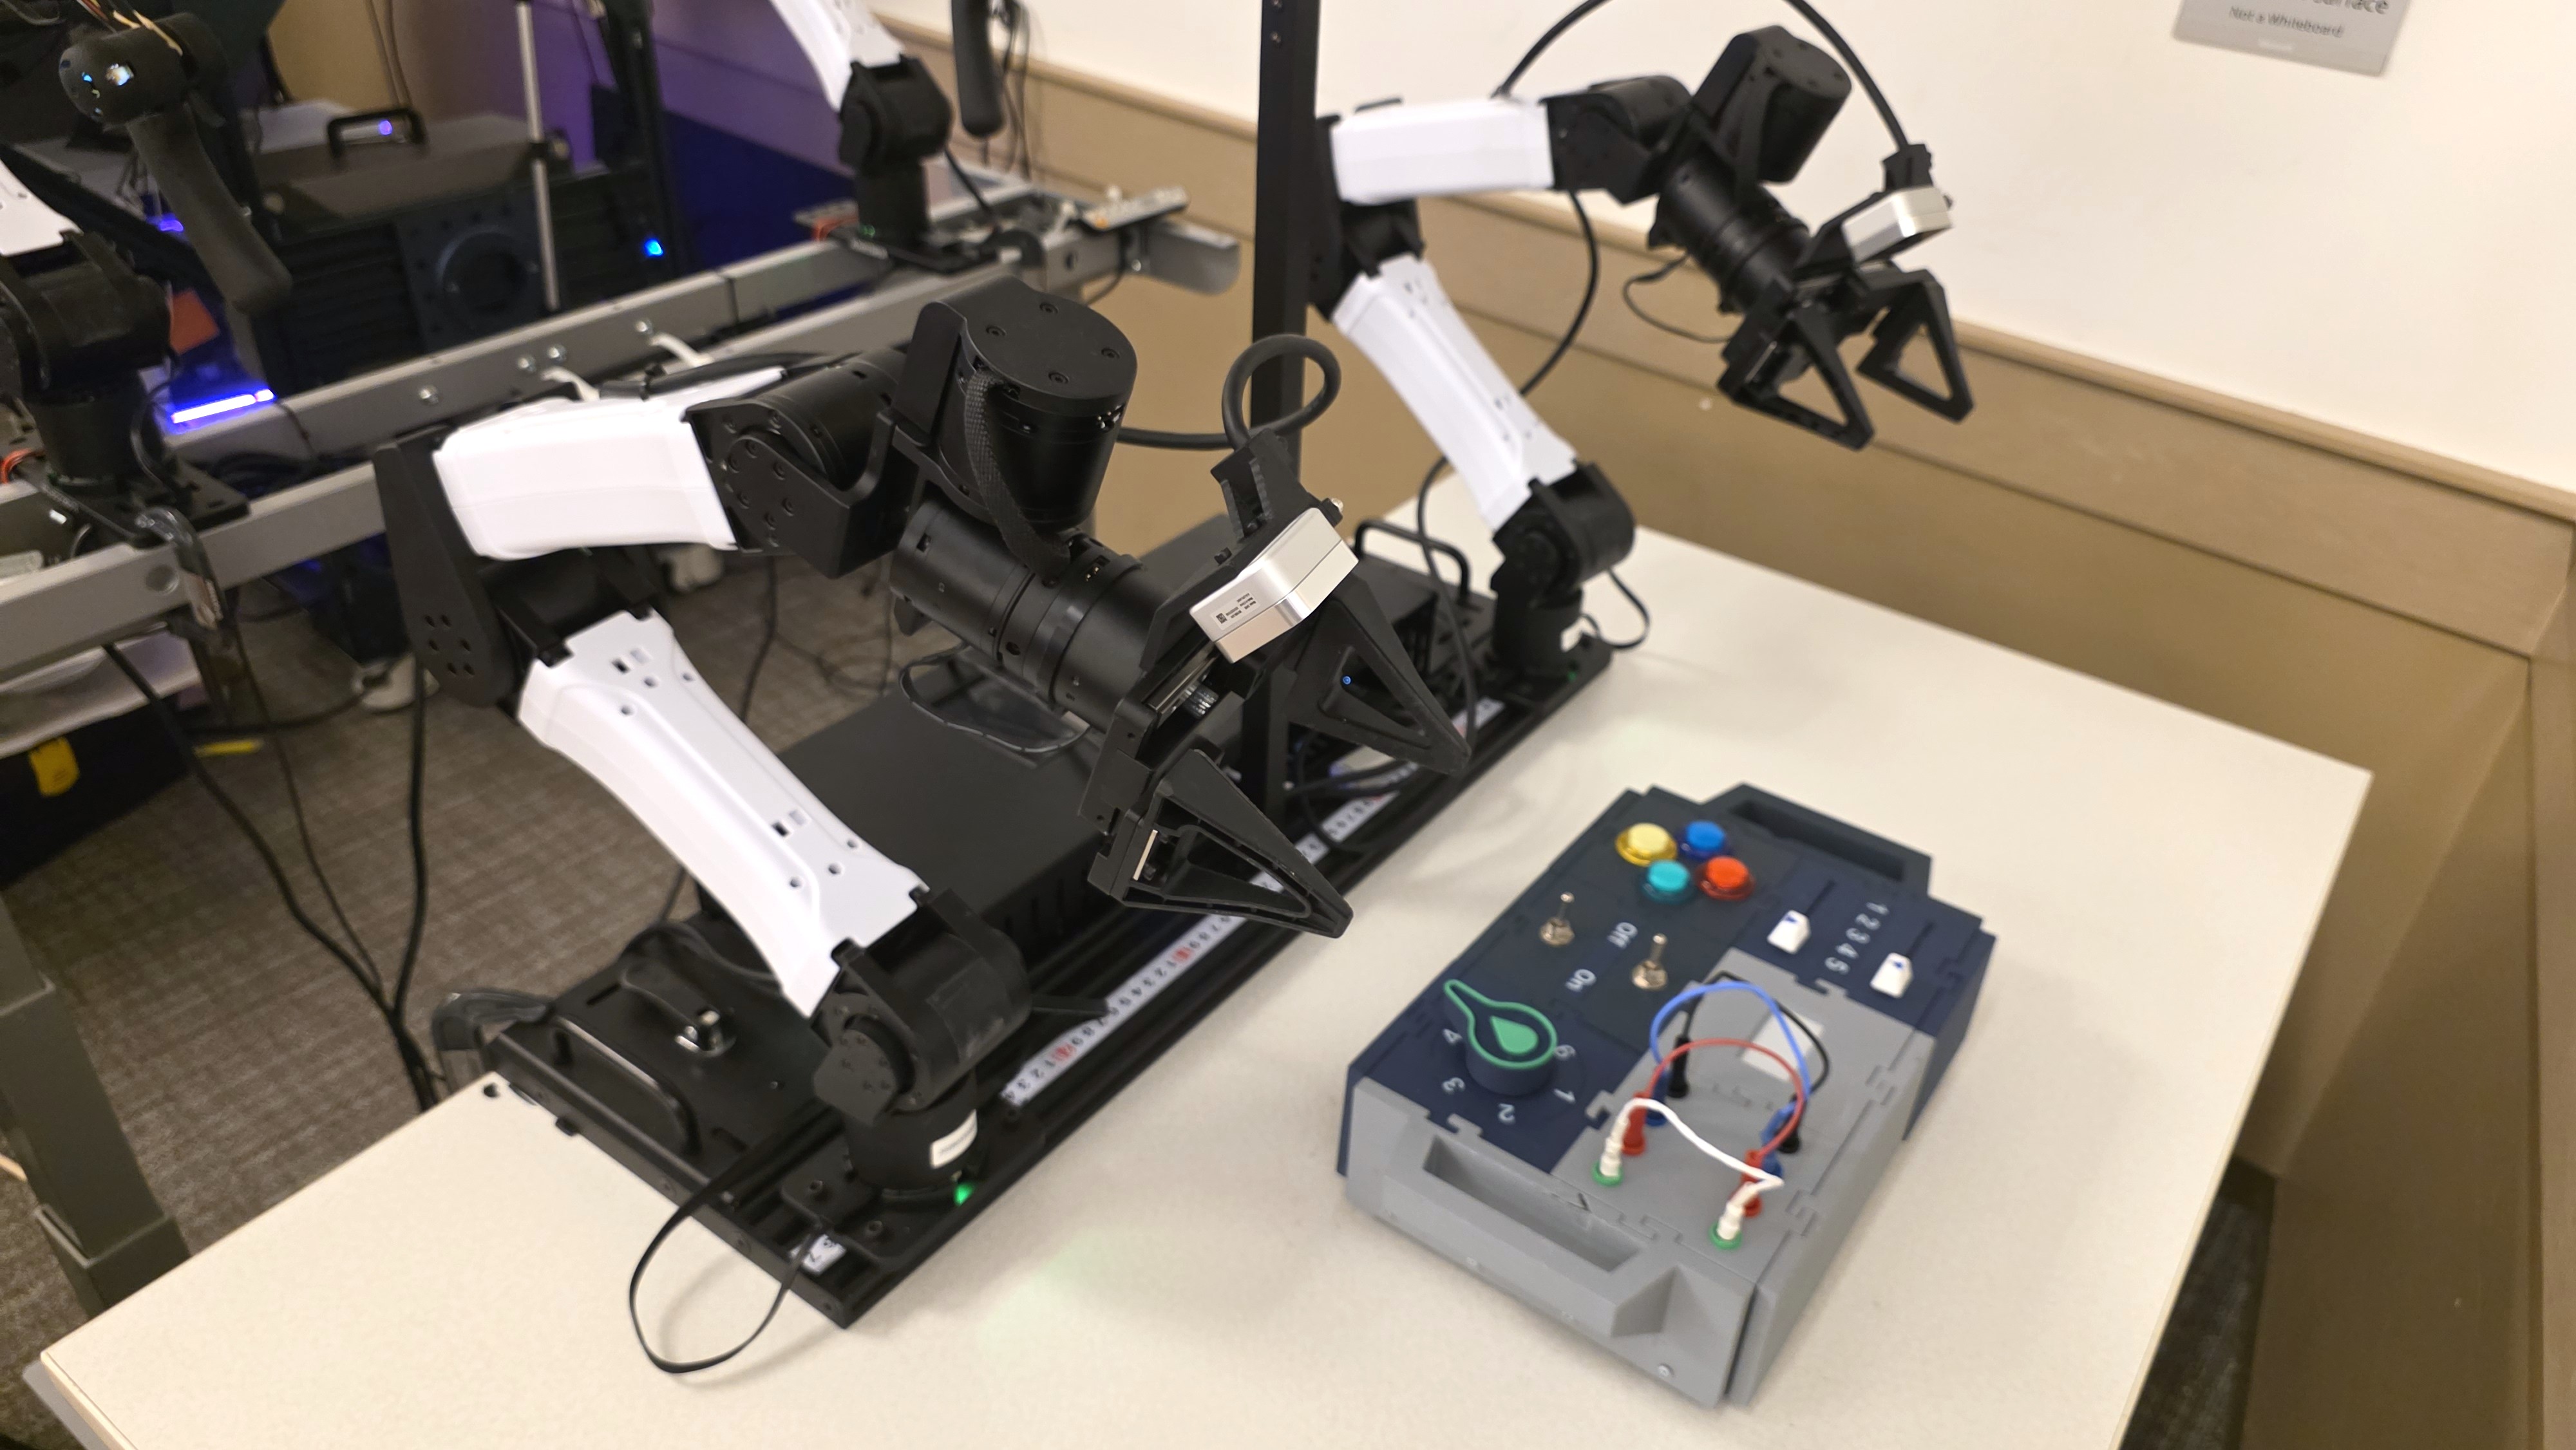
Simran Bagaria, Daphne Chen, Dean Fortier, Jianlong Fu, Michael Harrison, Tess Hellebrekers, Neel Joshi, Andrey Kolobov, Dalton Moore, Galen Mullins, Michael Murray, Eduardo Salinas, Reuben Tan Microsoft Research, January 2025–September 2026 project page Rho is a family of open-weights 5B-parameter vision-language-action (VLA) models for bimanual robotic manipulation. By separating embodiment adaptation from task adaptation, Rho's midtraining pipeline produces robot-specific variants that need far less demonstration data to finetune to new tasks, and deployed policies keep improving from a handful of human corrections online. The Yam Box, one of three supported dual-arm platforms, pairs two 6-DoF arms and parallel-jaw grippers with three RealSense cameras, and serves as the basis for the BusyBox benchmark and its released dataset. |
|
FlowDAgger: Human-in-the-Loop Adaptation of Generative Robot Policies in Latent Space
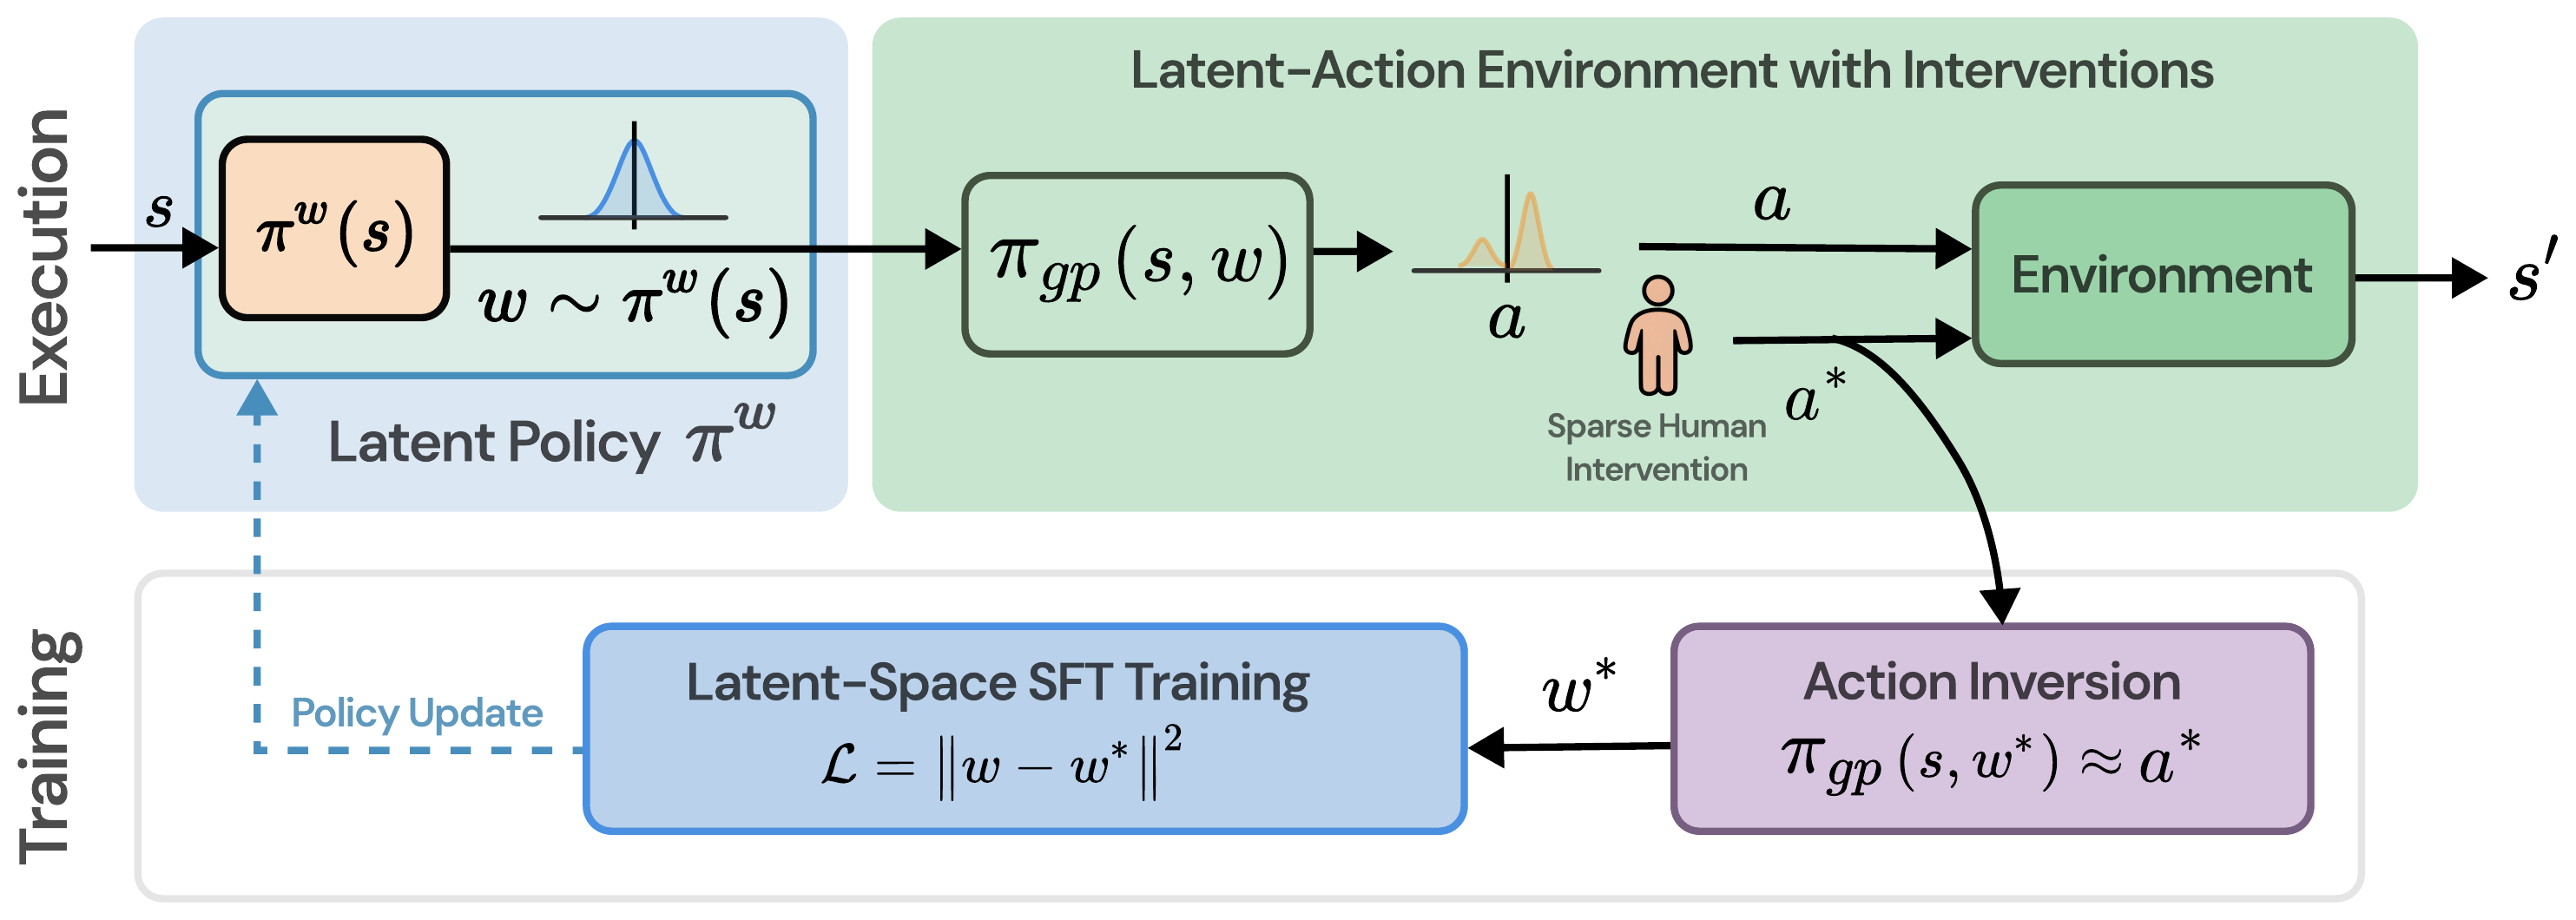
Michael Murray, Daphne Chen, Simran Bagaria, Dean Fortier, Tess Hellebrekers, Galen Mullins, Harshavardhan Gajarla, Oier Mees, Maya Cakmak, Andrey Kolobov arXiv, 2026 project page / arXiv / code FlowDAgger adapts frozen generative robot policies from human corrections without modifying base model weights. Using action inversion to map corrections into noise space, a lightweight latent policy steers frozen flow-matching and diffusion policies — preserving pretrained skills while achieving +0.25 mean success rate gains over frozen baselines with only a handful of interventions. |
|
Advancing AI for the physical world
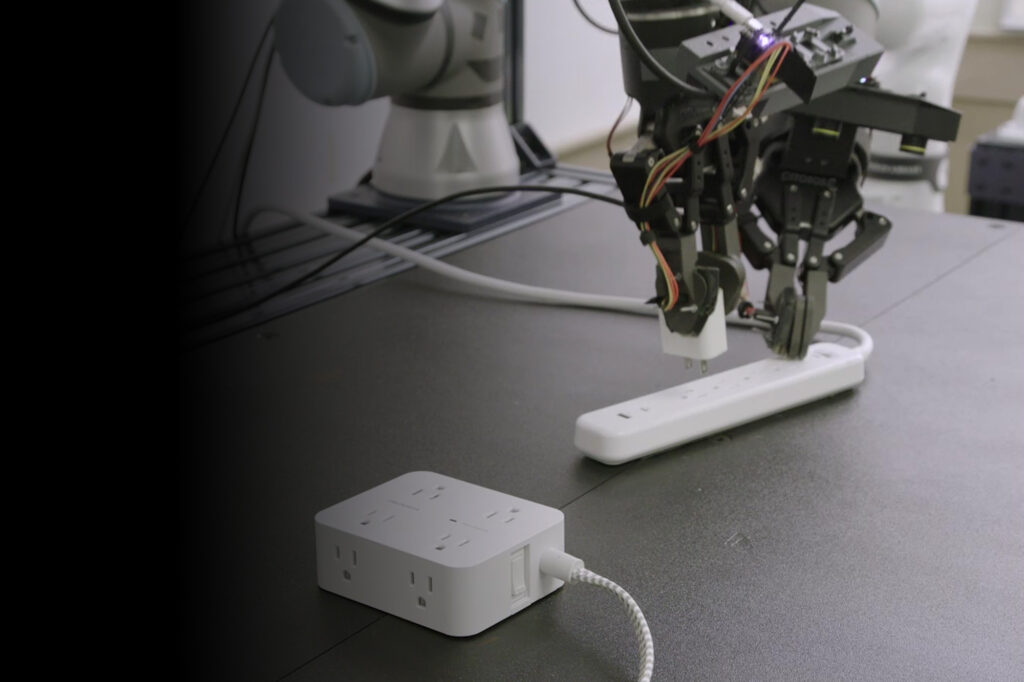
Andrey Kolobov, Galen Mullins, Tess Hellebrekers, Michael Murray, Dean Fortier, Simran Bagaria, Harshavardhan Gajarla, Ashley Llorens Microsoft Research Story, 2026 Microsoft Blog Post Announces Rho-alpha (ρα), a tactile-aware vision-language-action (VLA+) model for robot control that translates natural language commands into bimanual manipulation behaviors, evaluated across dual-arm platforms. |
|
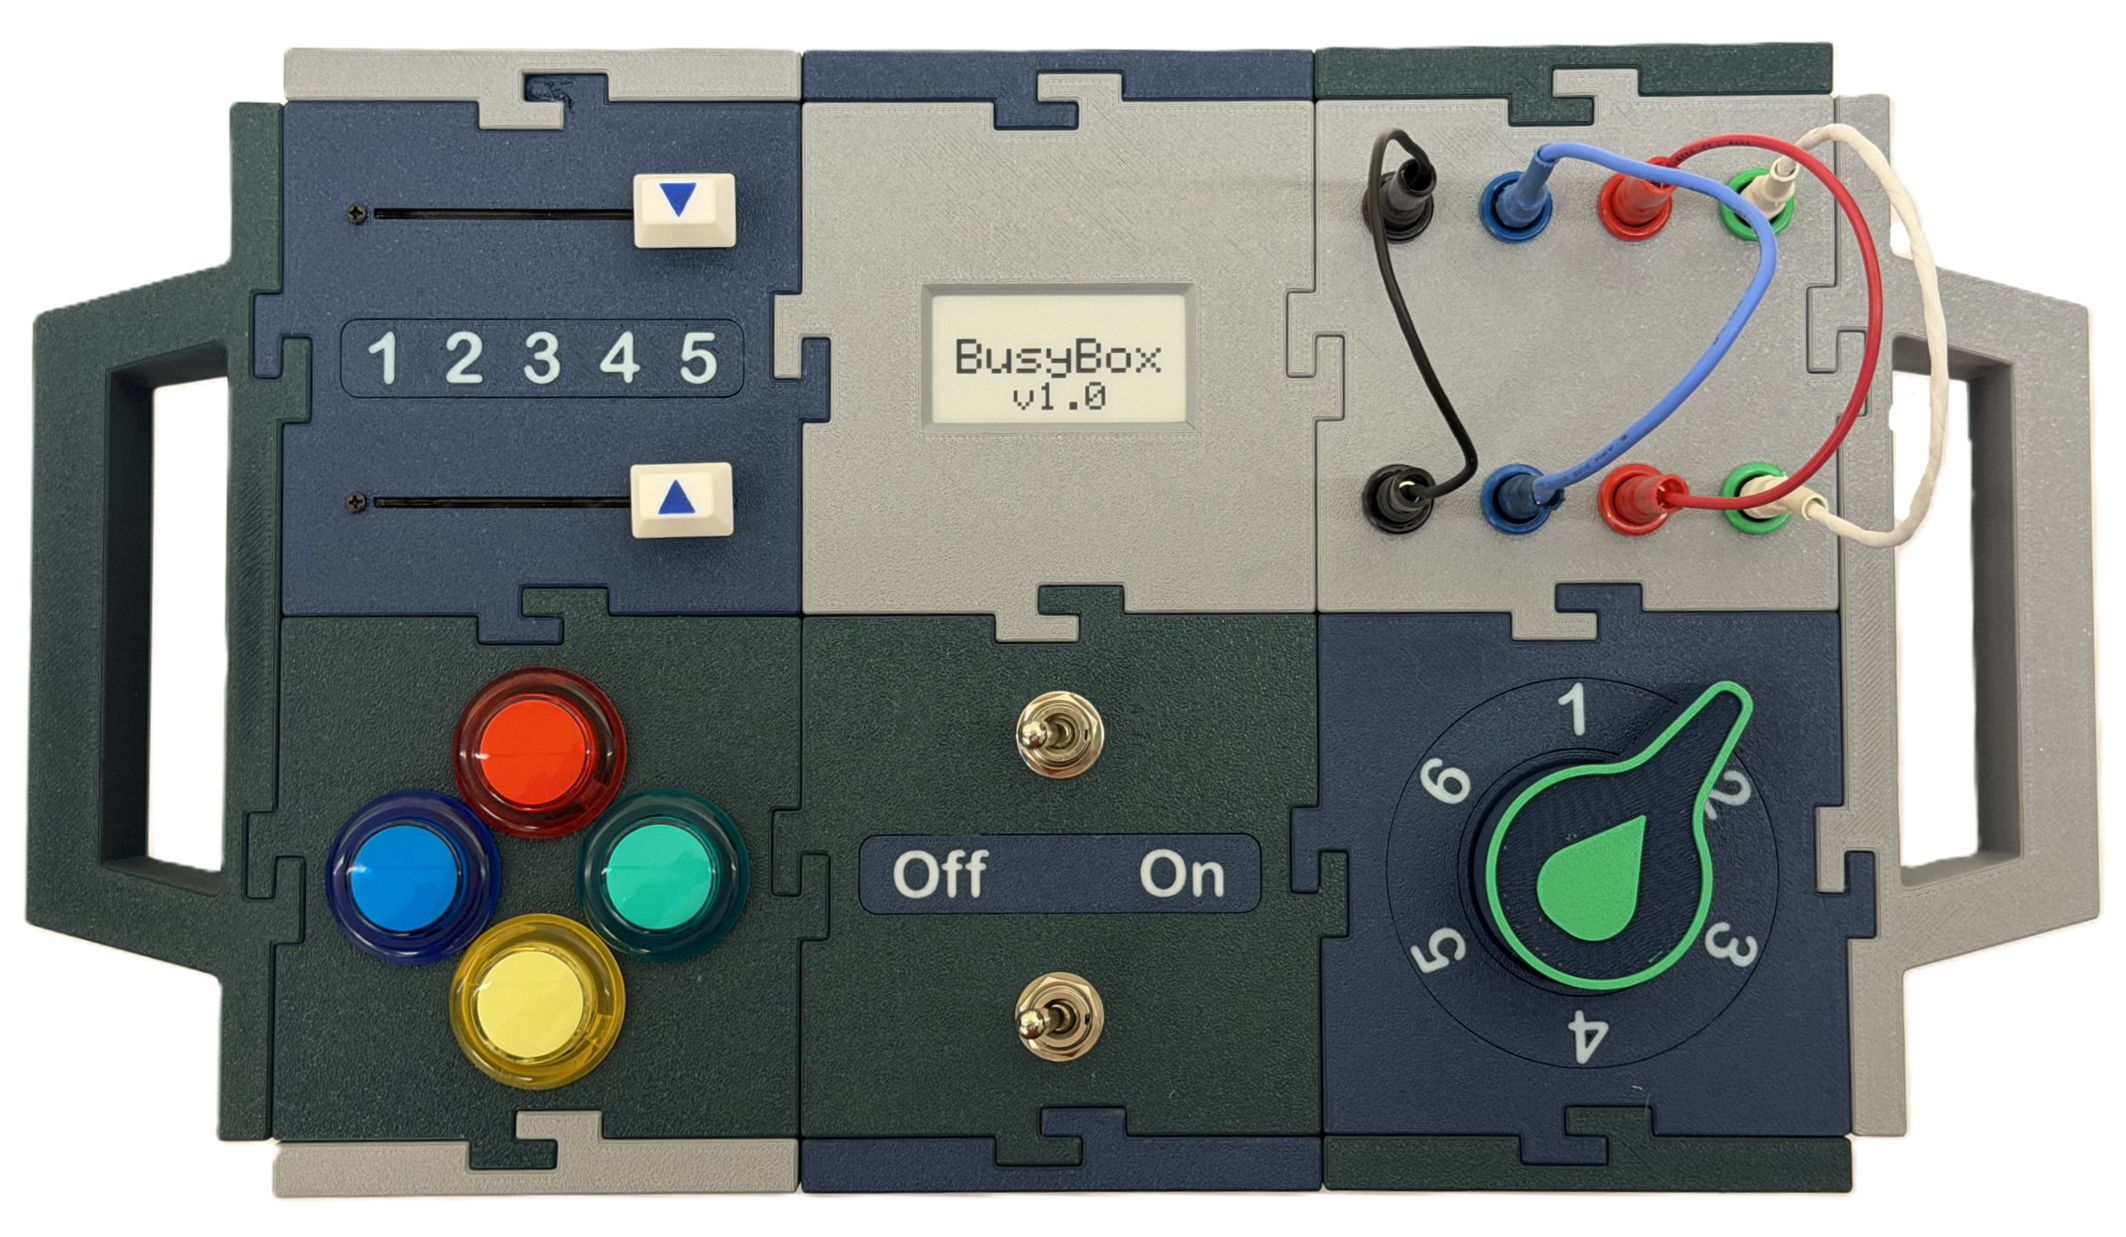
Benchmarking Affordance Generalization with BusyBox
Dean Fortier, Timothy Adamson, Tess Hellebrekers, Teresa LaScala, Kofi Ennin, Michael Murray, Andrey Kolobov, Galen Mullins Eval&Deploy Workshop at CoRL, 2025 project page Modular 3D-printable robotic manipulation benchmark for evaluating affordance generalization in robot foundation models. Email me for access to the associated dataset. |
|
LoLA: Long Horizon Latent Action Learning for General Robot Manipulation
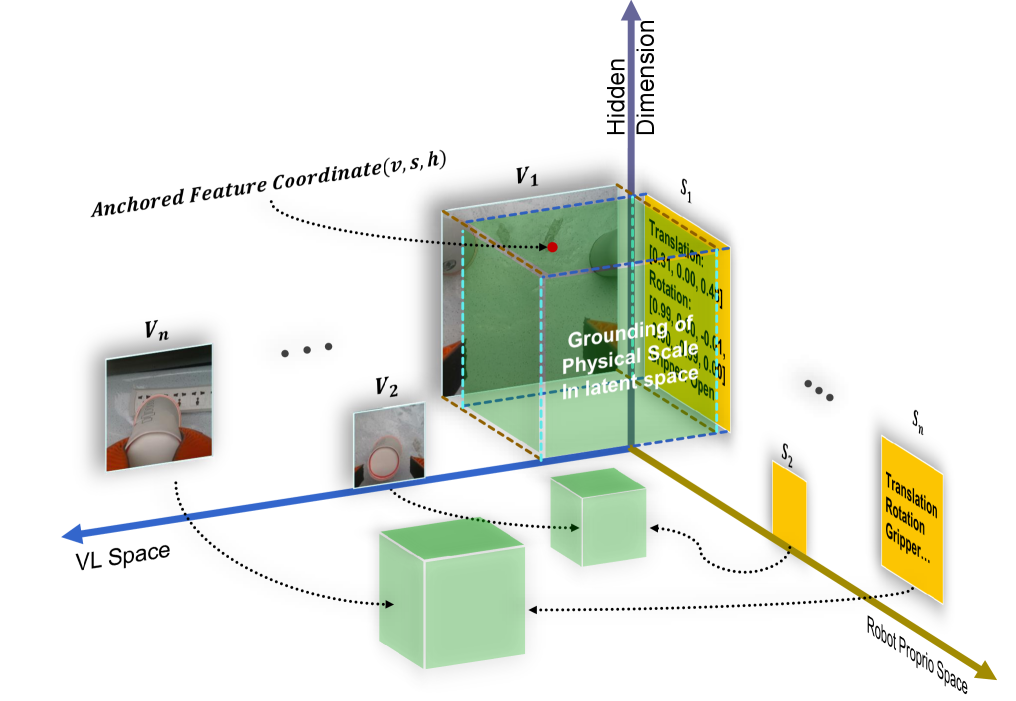
Xiaofan Wang, Xingyu Gao, Jianlong Fu, Zuolei Li, Dean Fortier, Galen Mullins, Andrey Kolobov, Baining Guo arXiv, 2025 arXiv / pdf LoLA is a VLA framework for long-horizon robot manipulation that integrates long-term multi-view observations and robot proprioception via a State-Aware Latent Re-representation (SALR) module, which grounds vision-language features in physical scale through an embodiment-anchored latent space. LoLA significantly outperforms prior methods (e.g., π0) on simulation and real-world benchmarks. |
Engineering PortfolioSelected engineering and robotics projects demonstrating practical system integration, prototyping, and deployment. |
|
|
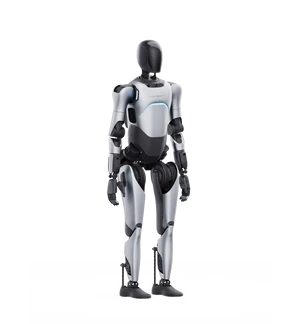
Box Packing and Manipulation on the Agibot A2
Dean Fortier, Matthias Bothe, Rushabh Jain for RoboService GmbH, July–September 2026 blog post Filled in on the team by advising on formalizing their model development pipeline: data collection, processing, and training techniques across different models. This saved the team time learning what data works and helped them deliver working robot models to Siemens. The task was box packing and manipulation for an Agibot A2 robot. |
|
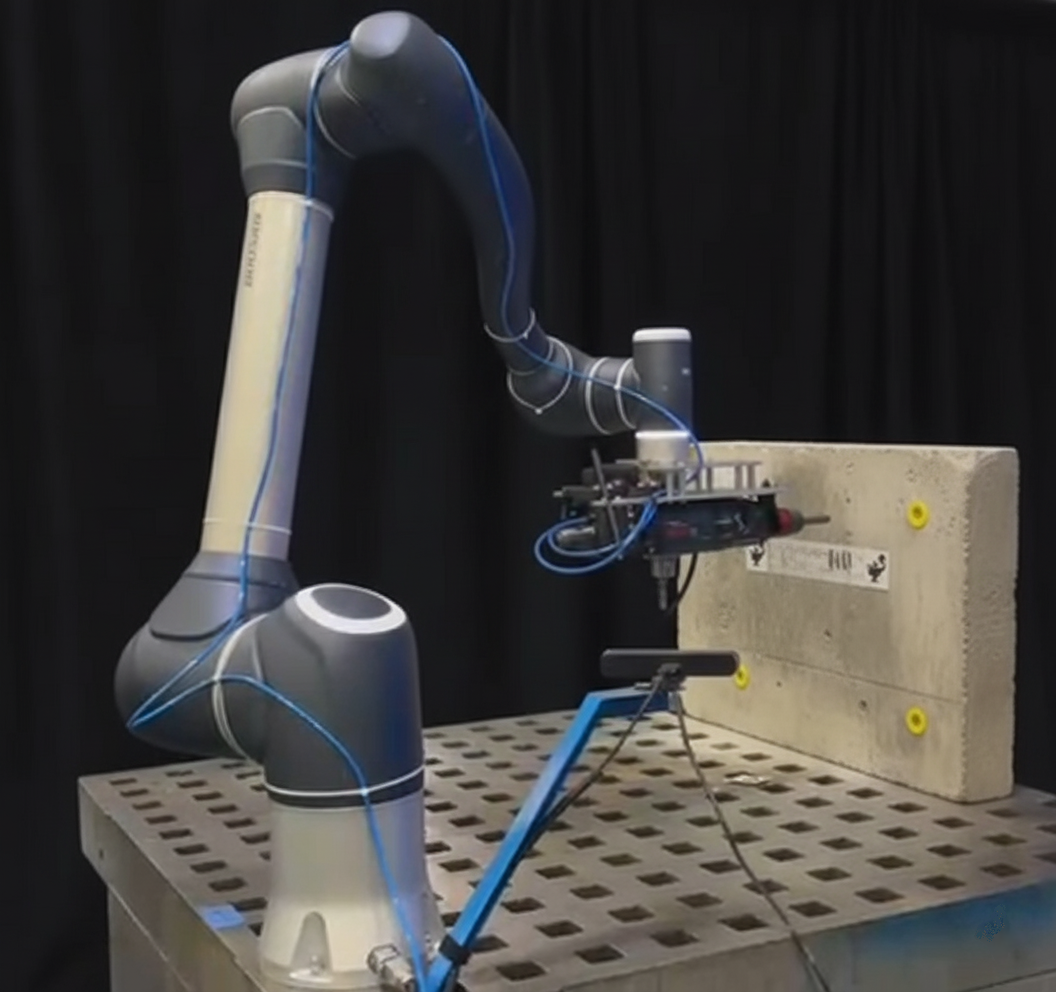
DrillSense
Dean Fortier, Timothy Adamson, Mitch Tolson for Genie Robotics, July 2025 DrillSense blog post DrillSense is a demonstration of an onsite journeyman level physical AI assistant. This assistant was capable of combining the accuracy of computer vision and robot control with high level reasoning and collaboration using OpenAI voice AI. |
|
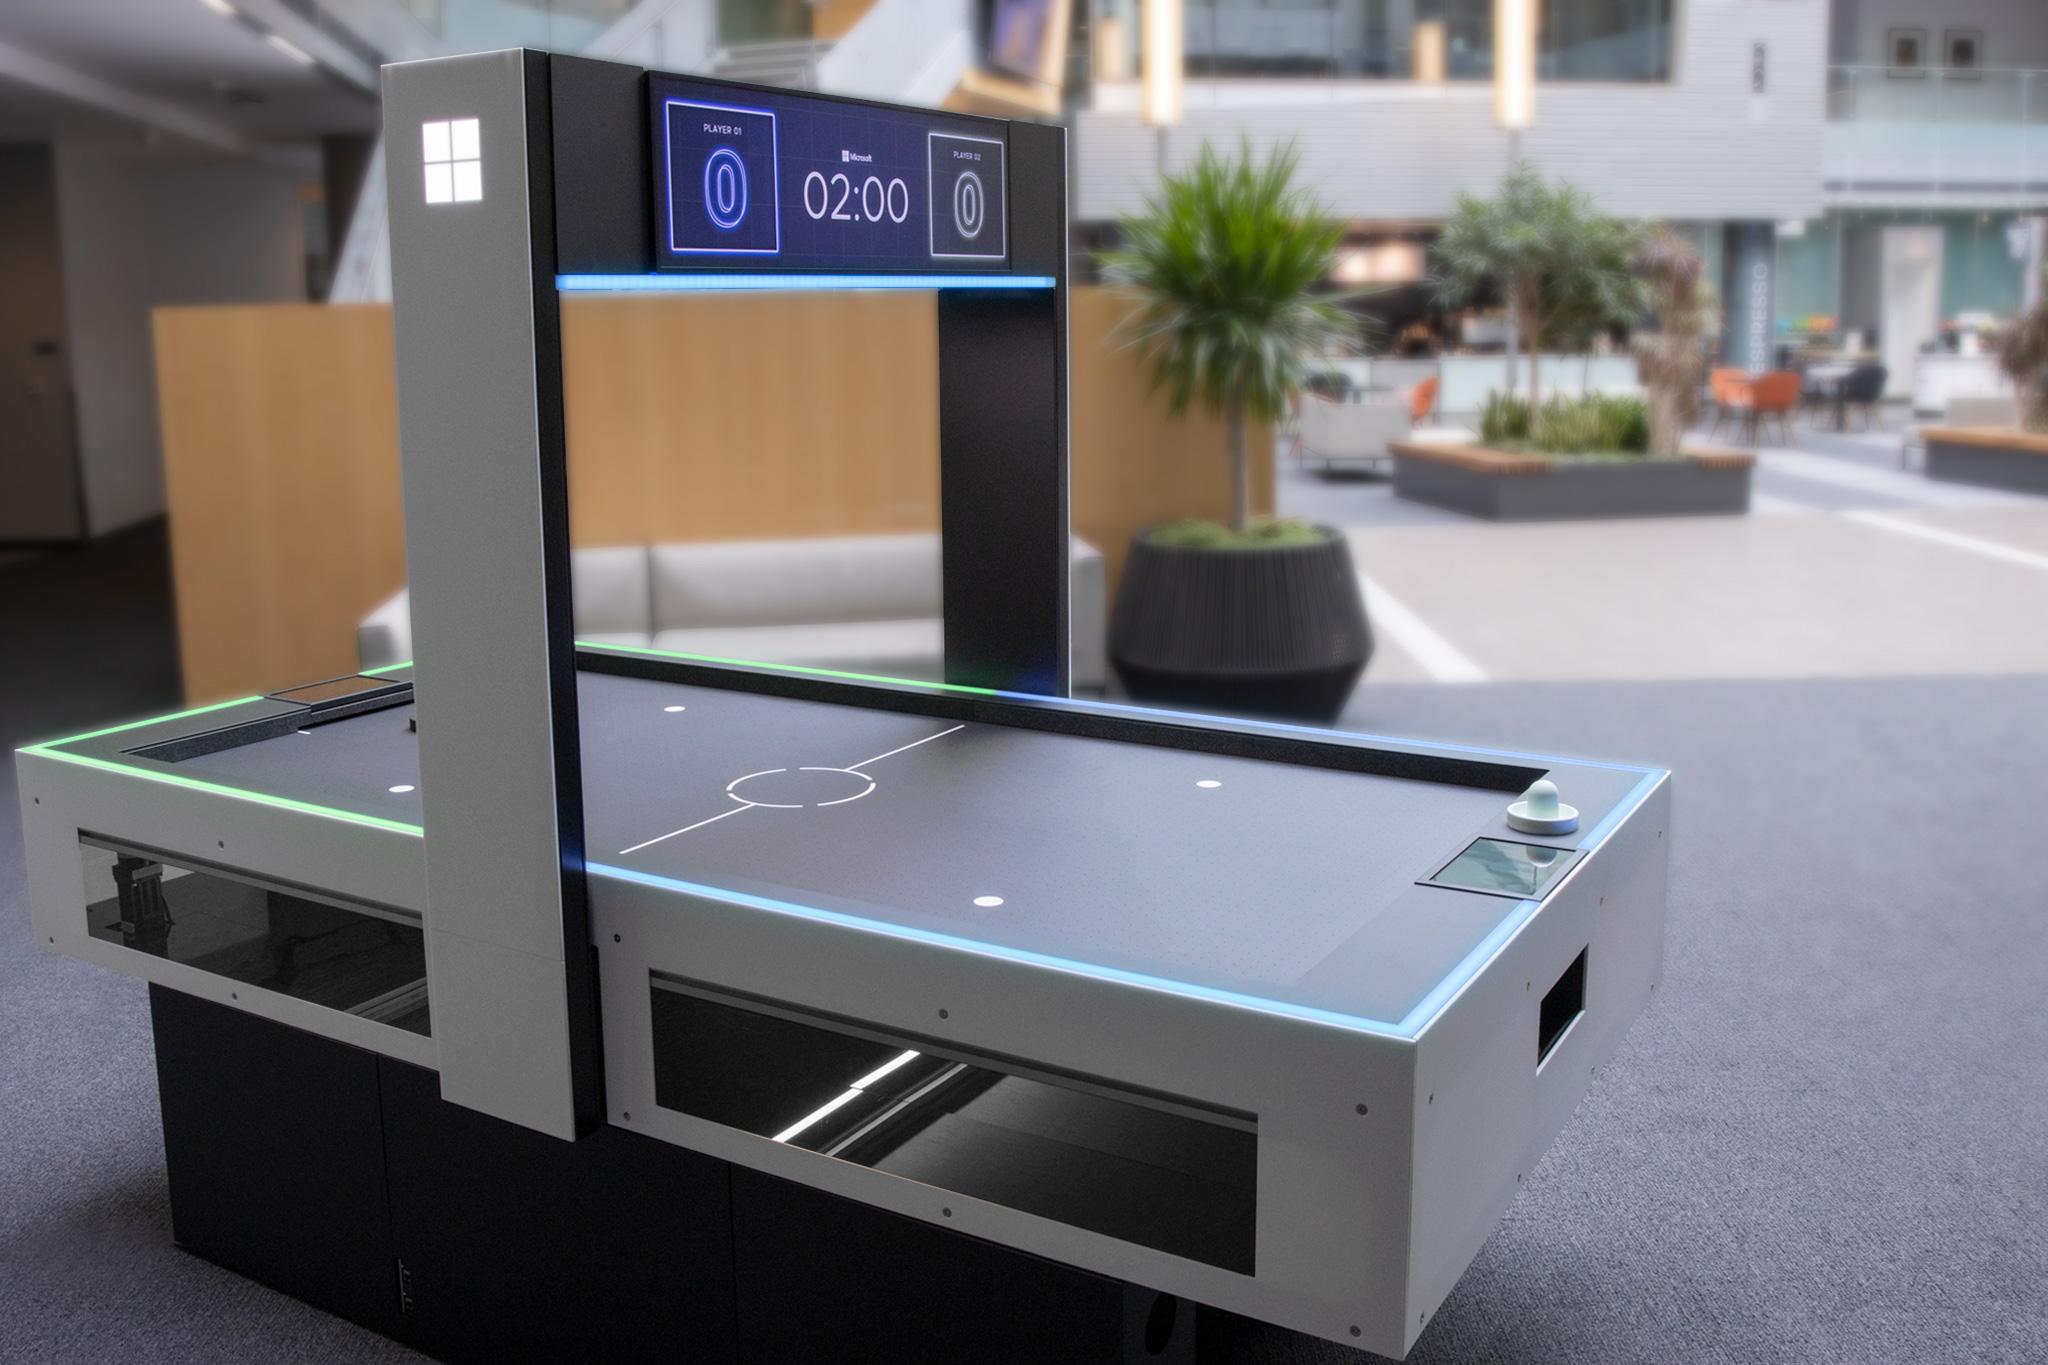
Robotic Hockey table
Scotty Paton (Design), Nissa van Meter (Electrical), Dean Fortier (Controls/Vision), Sam Sanders (PM), Richard Johnson (Tech), Grant Ritter (Mechanical) Microsoft Ignite 2020 Fresh Consulting Blog Post Microsoft AI partnered with us to develop a promotional hardware piece for the Autonomous Systems group. They needed a bold platform to deploy, test, and interact with AI models created with Project Bonsai. I built out the vision, calibration, and controls systems. |
|
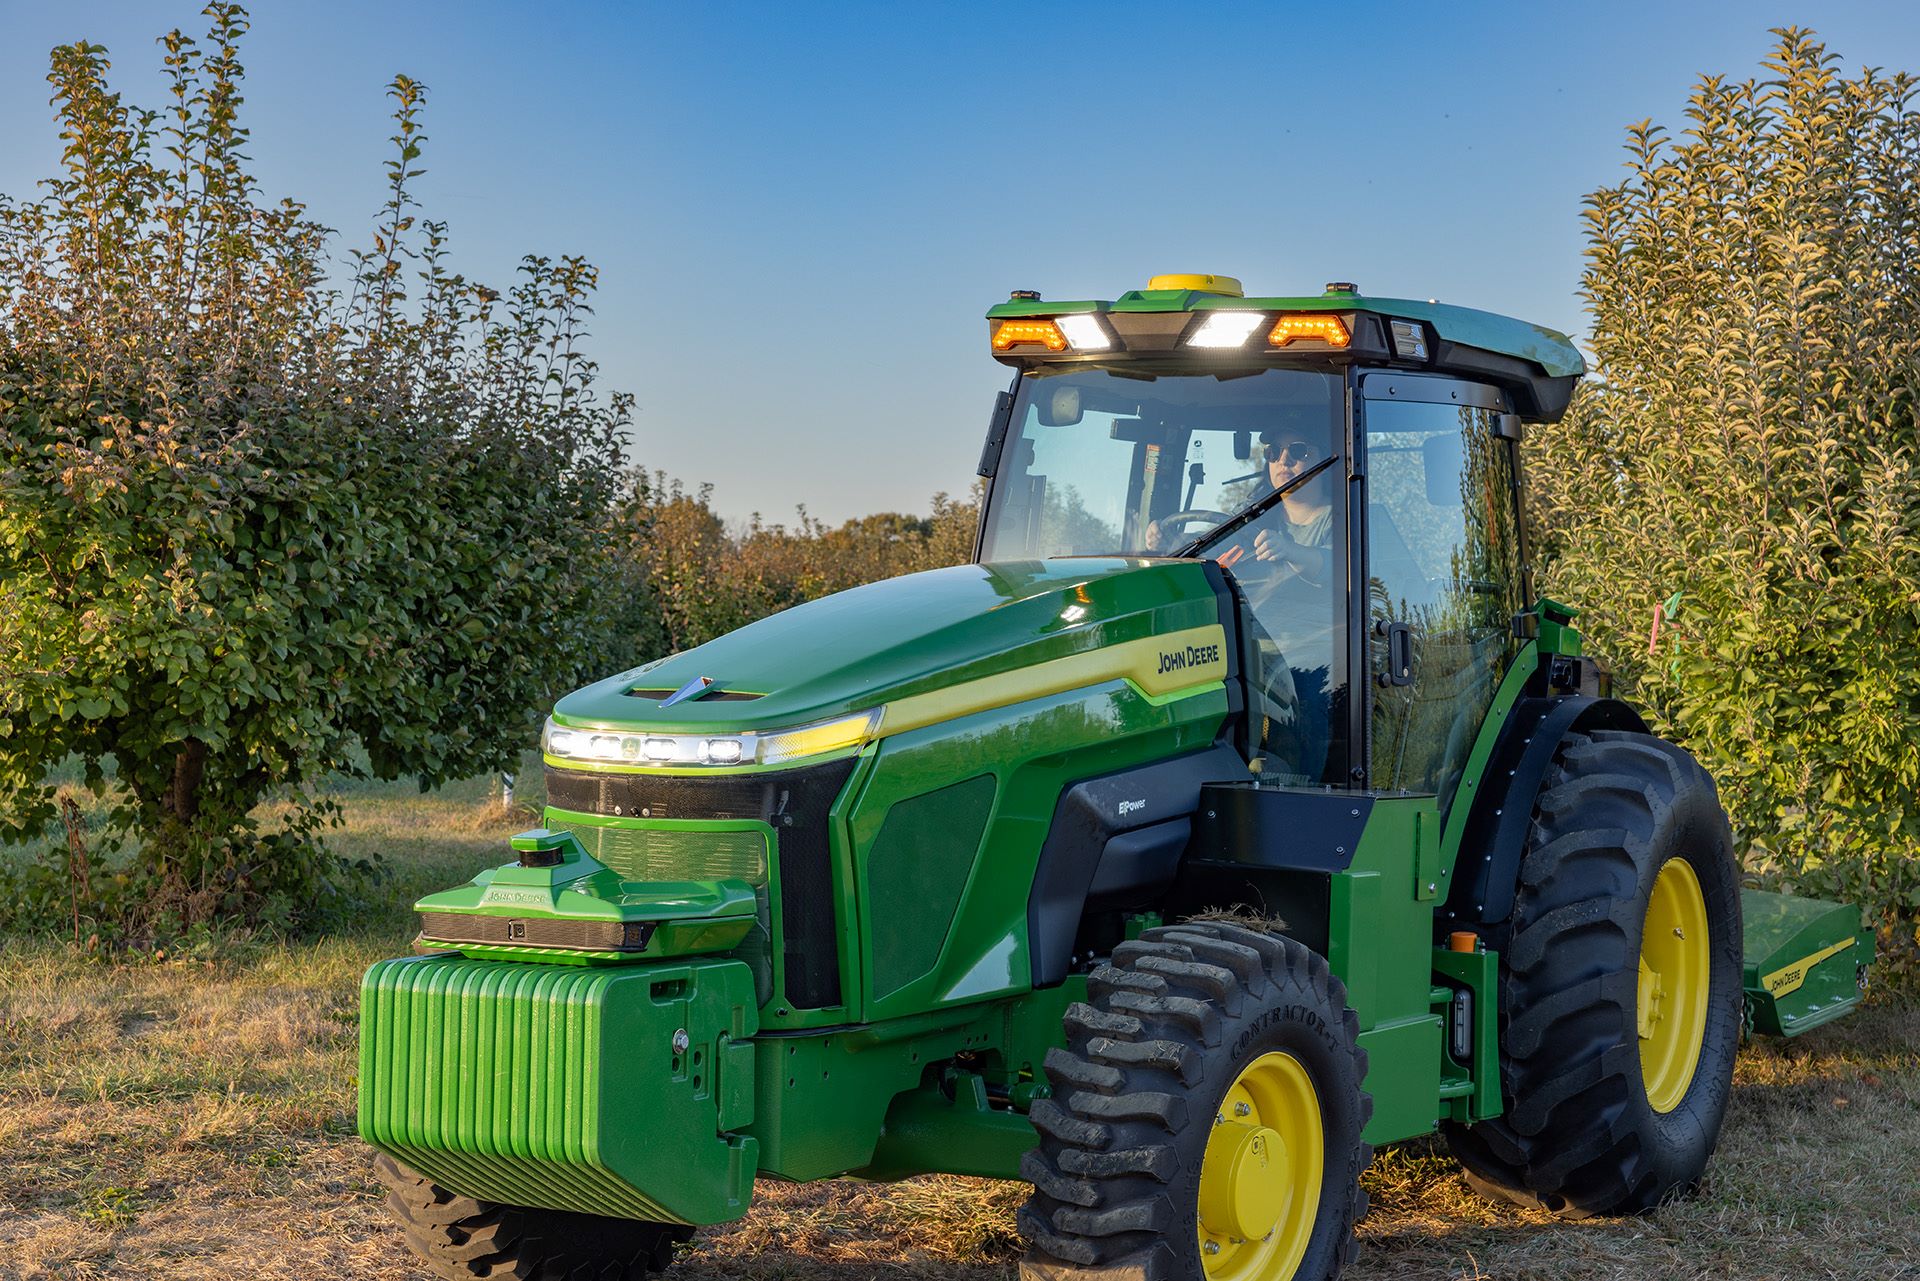
Crowsnest - Tractor Bird's eye view
Dean Fortier, John Houston, Vishal Prabhu for John Deere R&D 2022 We developed a multi-camera calibration system using visual fiducials printed on inter-locking floor mats to cover an arbitrarily wide area. This calibration system determines the 6D pose of each camera and projects all camera images onto a single plane allowing for a simulated 360° view around the tractor. |
|
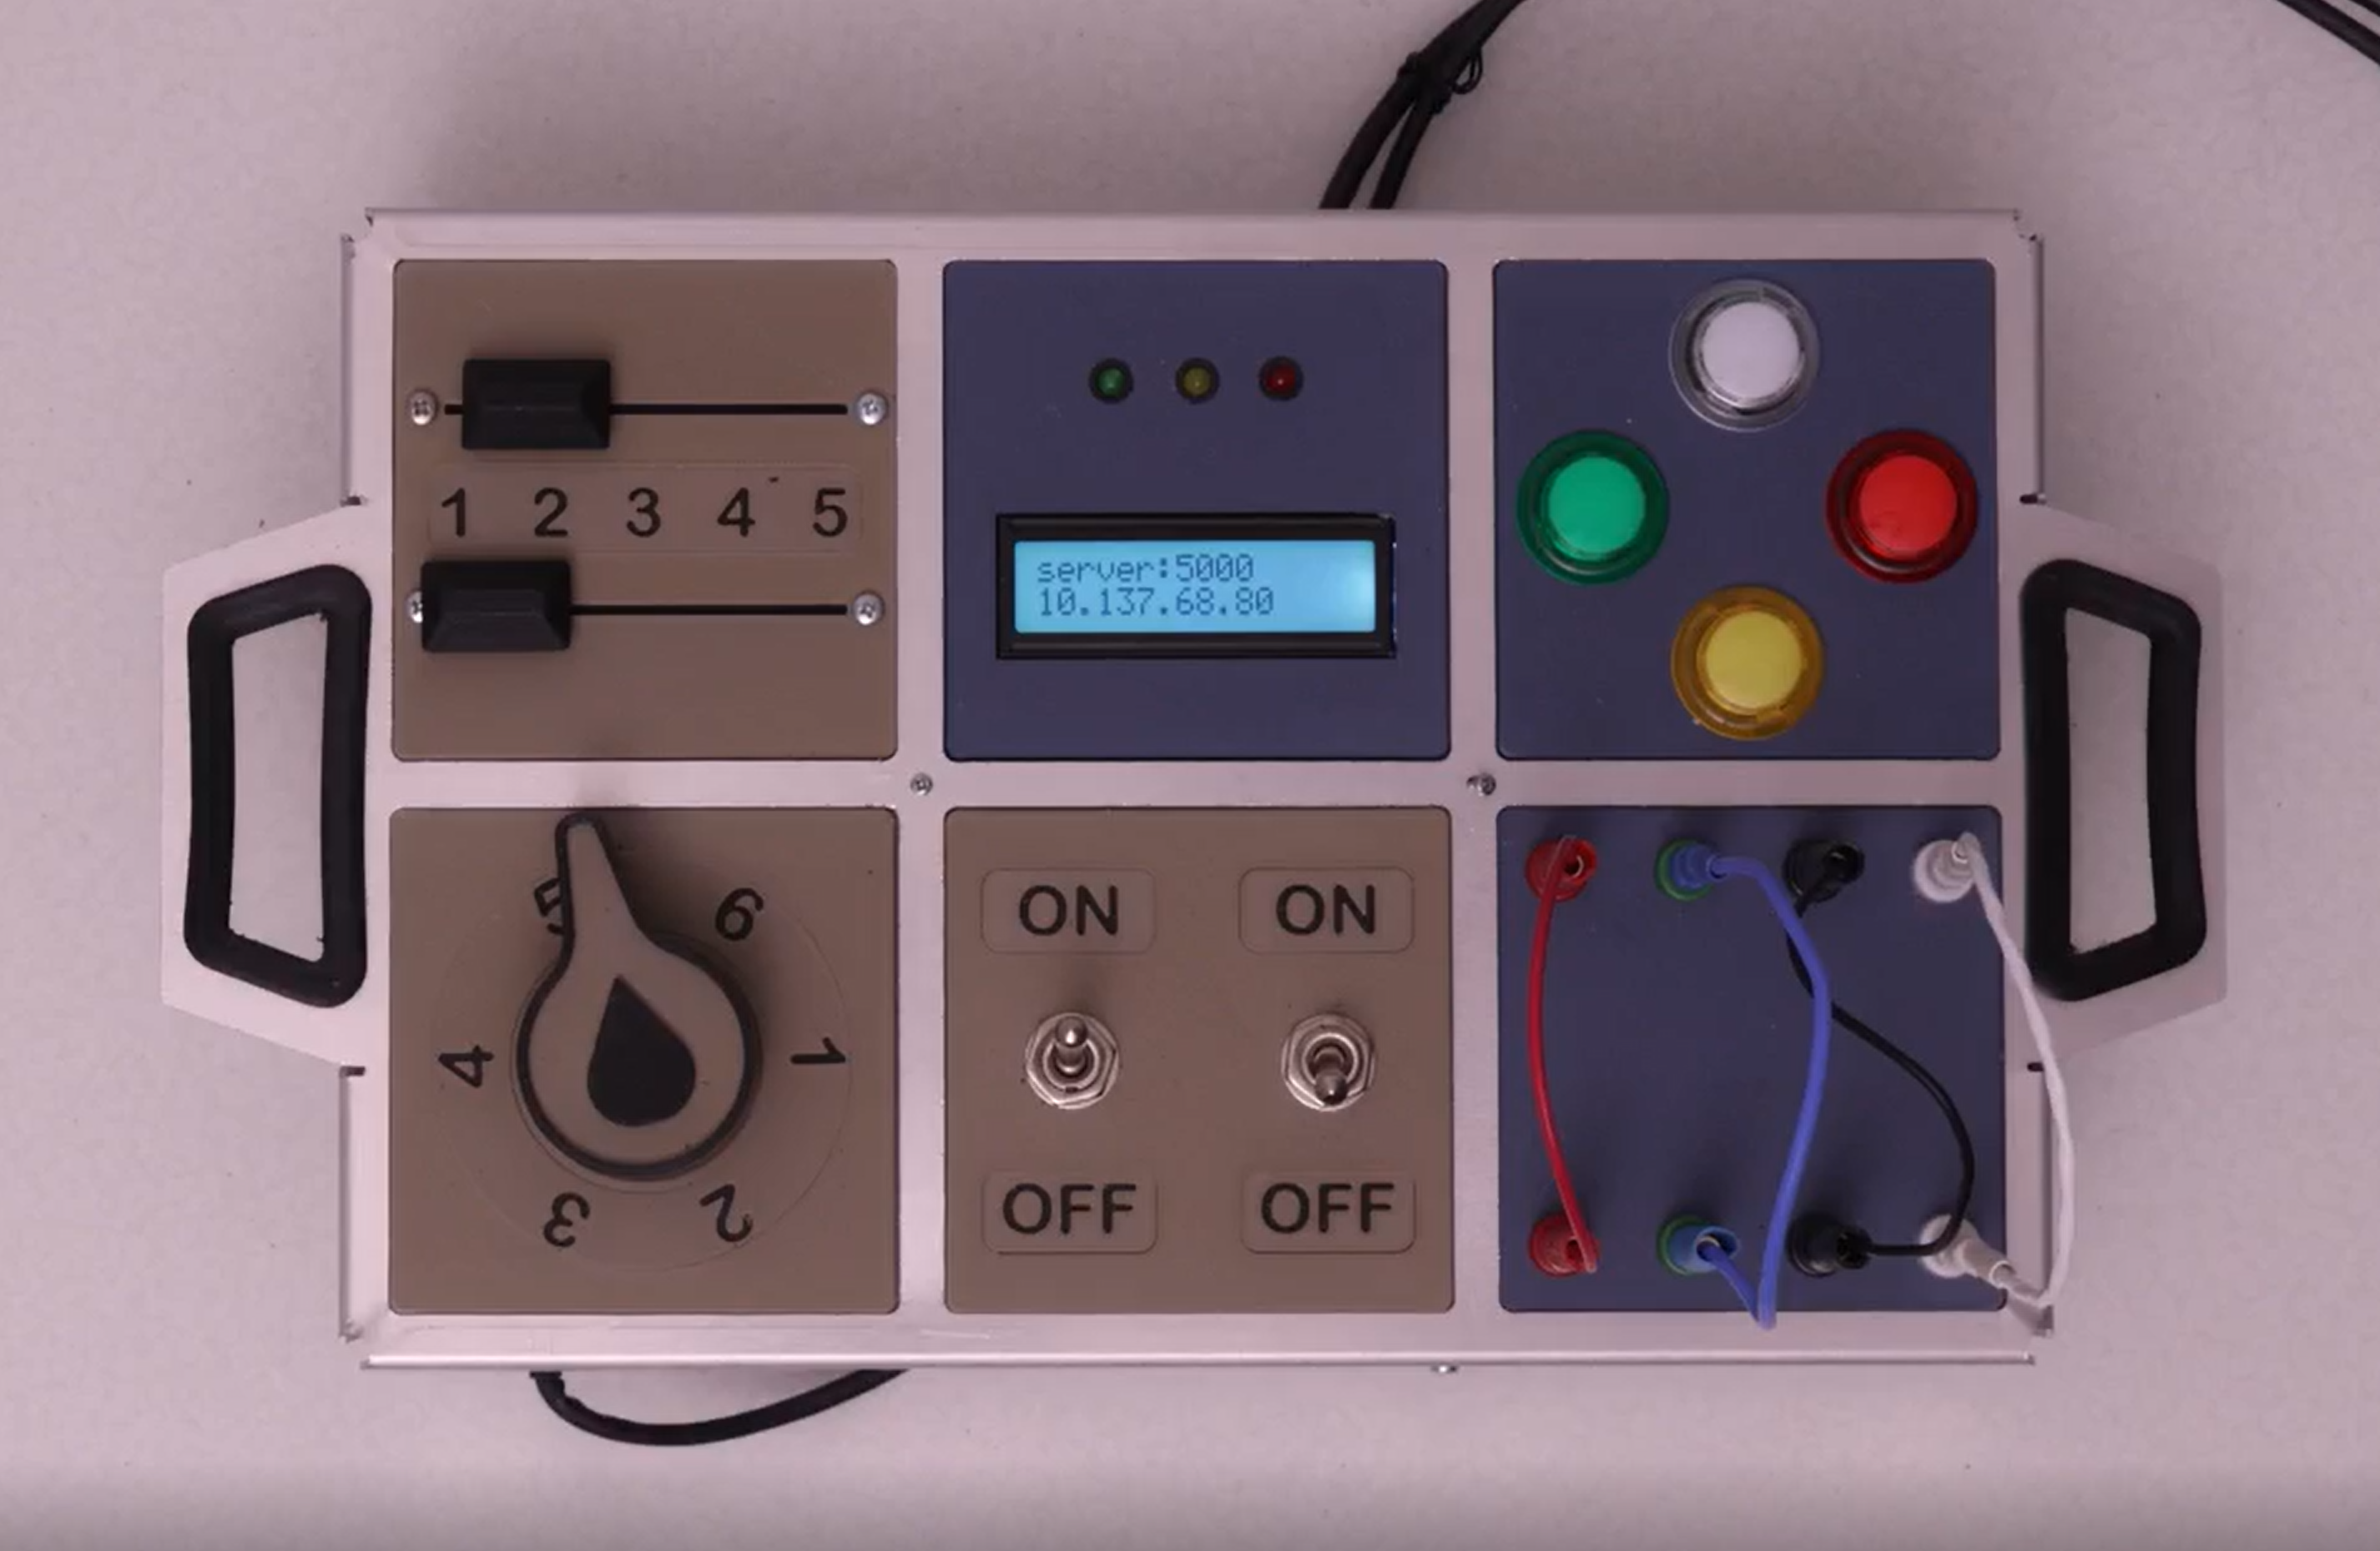
Interactive BusyBox Manipulation
Galen Mullins, Dean Fortier, Timothy Adamson Microsoft Project Green 2025 blog post We showcase an agentic system consisting of a voice agent front end for interacting with a user, a VLM to observe the state of the BusyBox, and a VLA to control bimanual manipulation of the Busybox |

|
Optitrack ROS Support
Dean Fortier, Stuart Guarnieri github link This ROS2 driver allows Optitrack's NatNet streaming service to connect to robot applications easier. |
|
Website template -> here! |